FIRST LEGO League Challenge · BIOGLOW Season

Seven kids in Castlegar,
building something bigger than a robot.

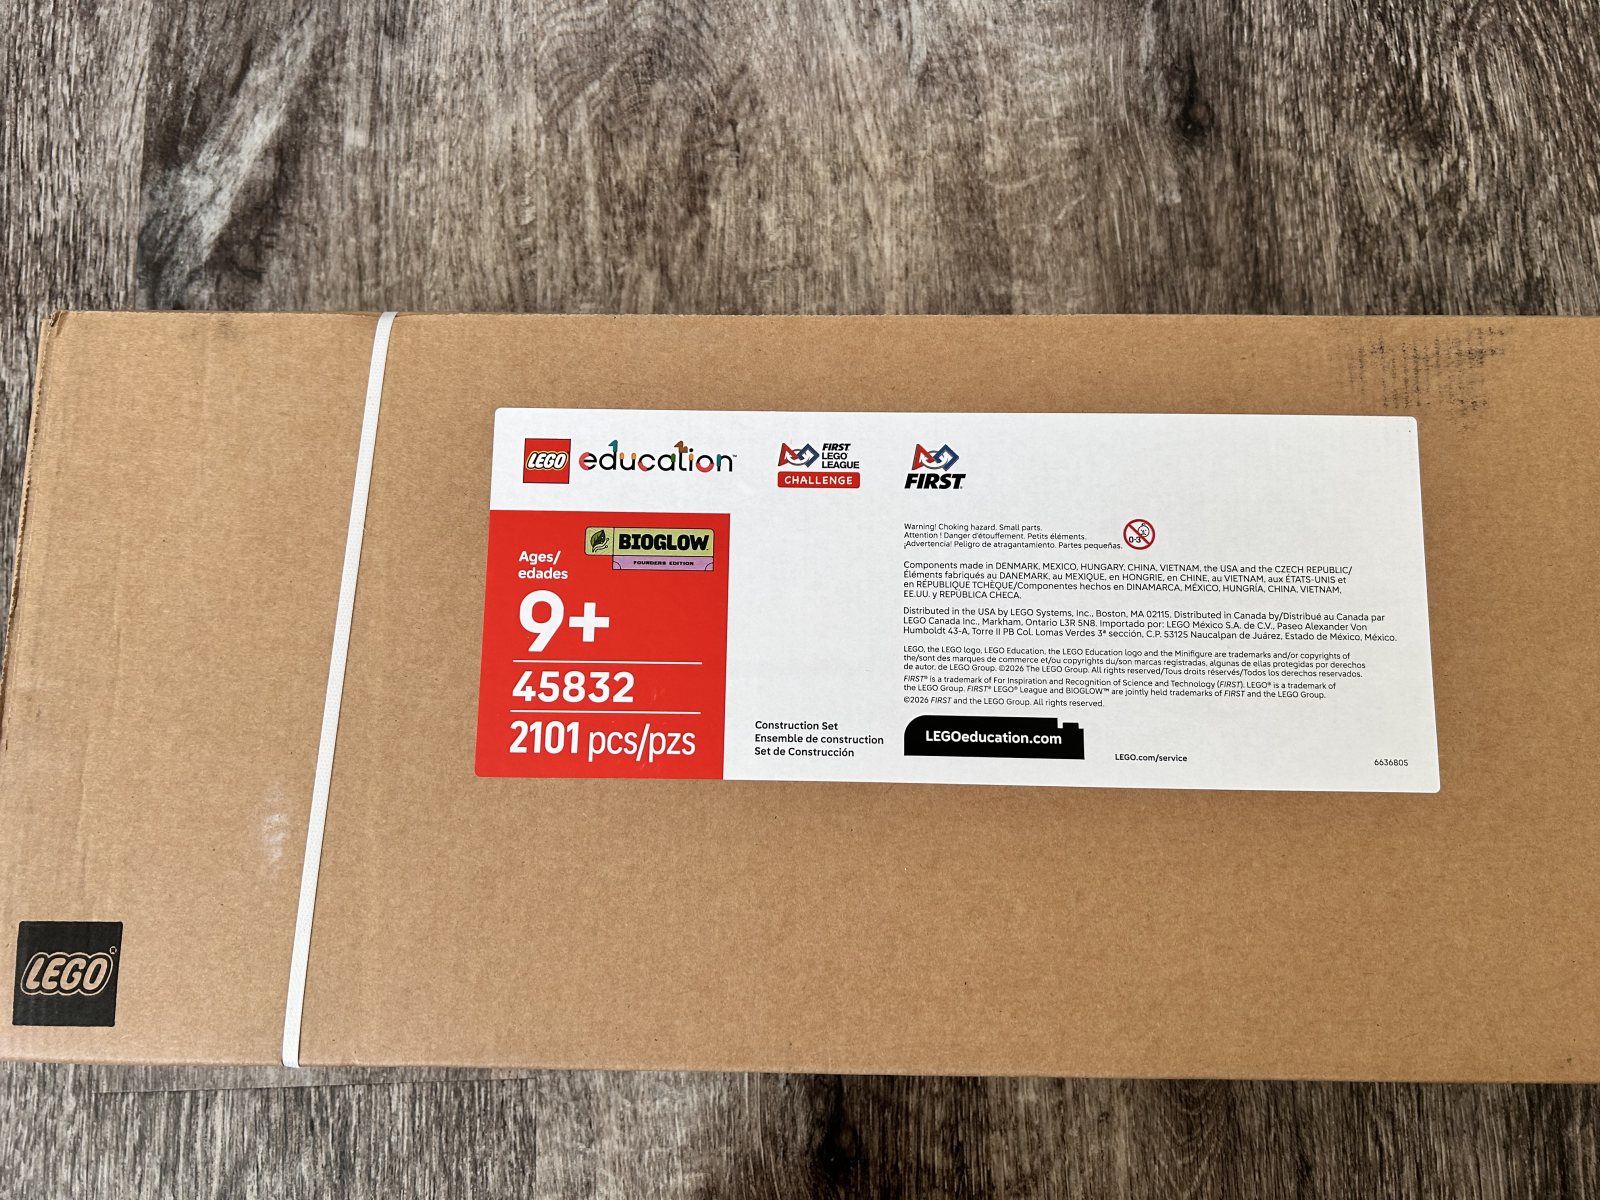
Team Castlegar Robot represents our community in the 2026 to 2027 FIRST LEGO League Challenge. We build and program a robot, research biodiversity in our own backyard, and pitch a real solution to real judges.

Team Castlegar Robot logo
images/logo.png
will appear here once uploaded

This season

BIOGLOW: living systems and biodiversity

Every FIRST LEGO League Challenge team tackles two halves of the same problem: the Robot Game on the table, and an Innovation Project in the real world.

Robot Game

We design, build, and program an autonomous robot to complete missions on the competition table, scored on precision and repeatability.

Innovation Project

We are finding an actual problem tied to biodiversity or ecosystems in Castlegar, then designing an idea that could genuinely help.

Final Pitch

We share our idea with our community, gather feedback, refine it, then present it to judges in a five minute pitch on competition day.

Member

Who makes up the team

Team, coaches, and the staff supporting us behind the scenes. Names and photos are on their way.

Team 8 including observers

01
Noah Kang
Competitor
02
Lyla Choi
Competitor
03
Dilan Kim
Competitor
04
Jiho Jeon
Competitor
05
Siwon Kang
Competitor
06
Hwijun Shim
Competitor
07
Sian Lee
Competitor
08
Jun
Competitor
Observer

Coach 2

C1
Albert Kang
Head coach
C2
Samuel Song
Assistant coach

Staff

S1
Kelly Bak
Team support

Train

How we practice

We meet weekly to build, test, and prepare for competition day.

Robot design and build

Assembling and refining the robot for the missions of this season.

Programming and testing

Writing and running missions again and again for accuracy.

Core Values

Practicing teamwork, gracious professionalism, and discovery in every meeting.

Innovation Project research

Talking with local experts and neighbours about biodiversity in Castlegar.

Team Castlegar Robot practice session
Photo coming soon
Photo coming soon
Photo coming soon

Report

Weekly log

A running record of what we build, learn, and fix each week. Updated after every meeting.

Meeting 06

Working as Specialized Teams

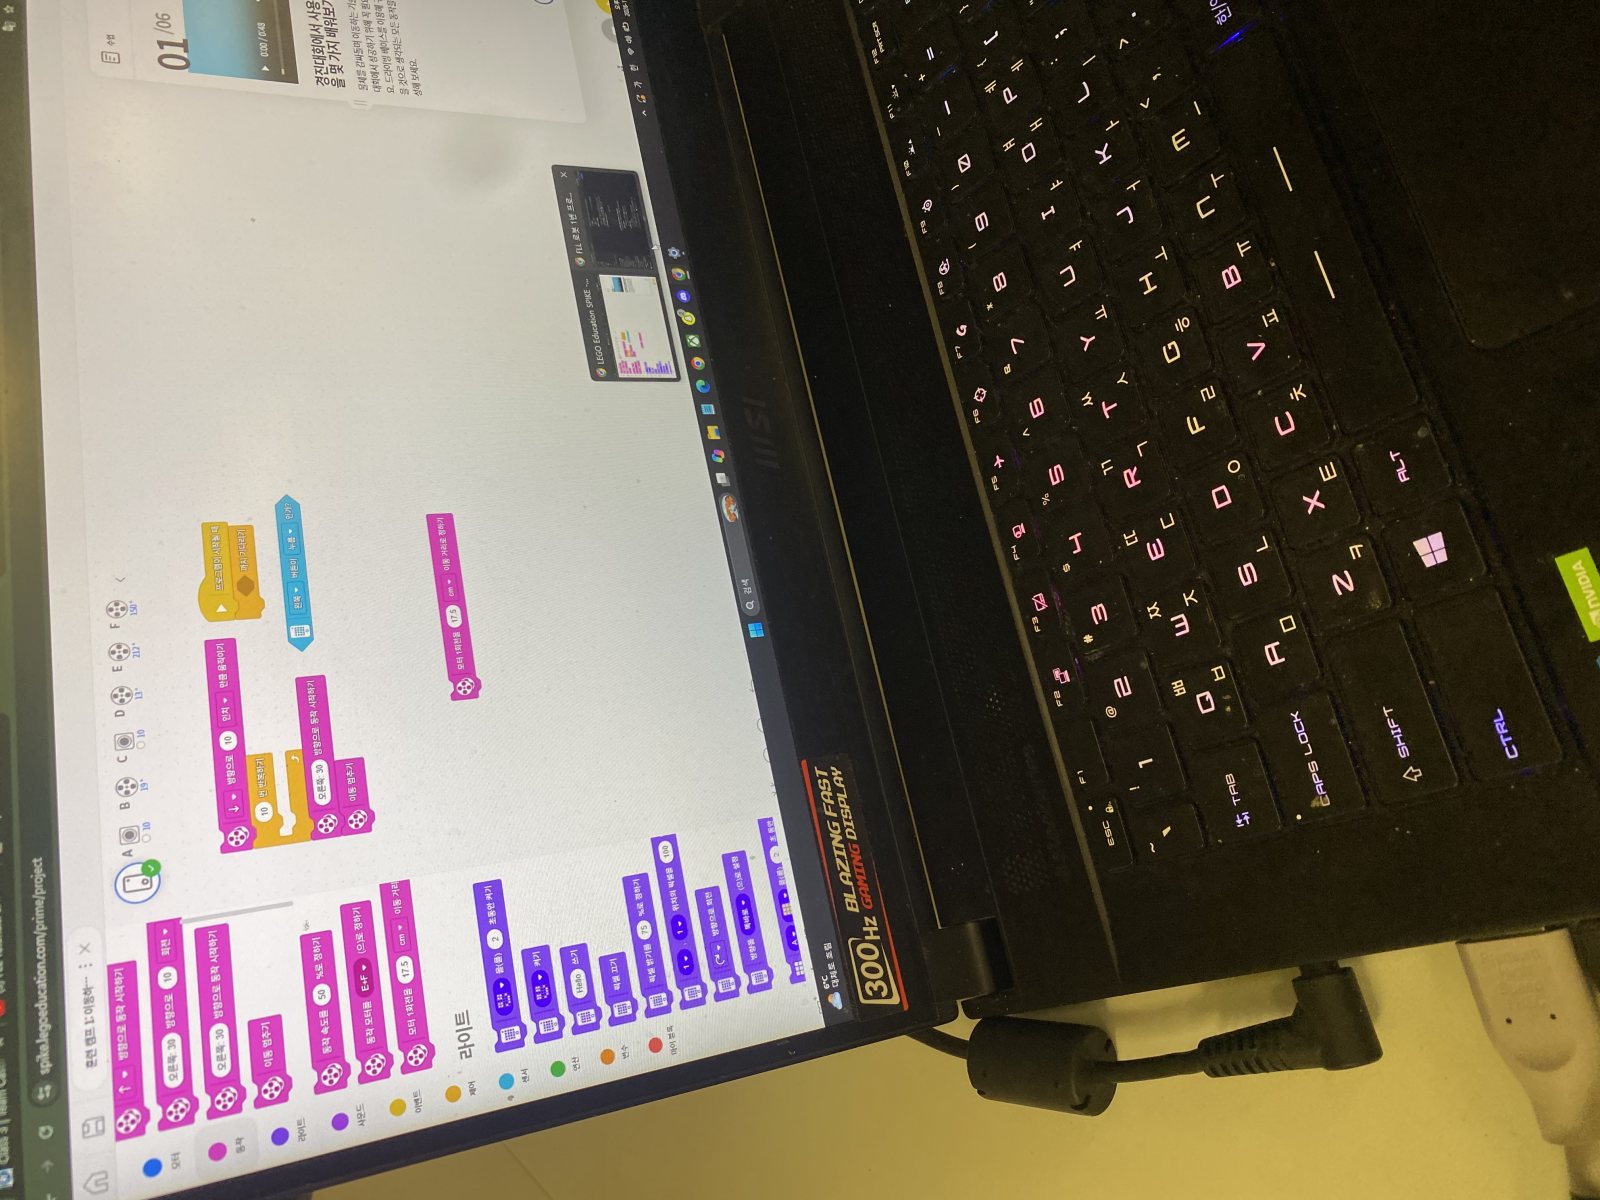
This week, we divided into smaller teams and began working on different parts of our FLL challenge. The engineering team started building an attachment for our first mission, the coding team began programming the driving base, and the research team discussed possible presentation topics and shared different ideas.

What we did

We worked in three smaller teams: Engineering Team — Started building an attachment for our first mission. Coding Team — Began programming the driving base. Research Team — Discussed possible presentation topics and shared a variety of ideas. We also explored how we could create movement without using a motor. This helped us think about simple mechanical systems and different ways to transfer force.

What we learned

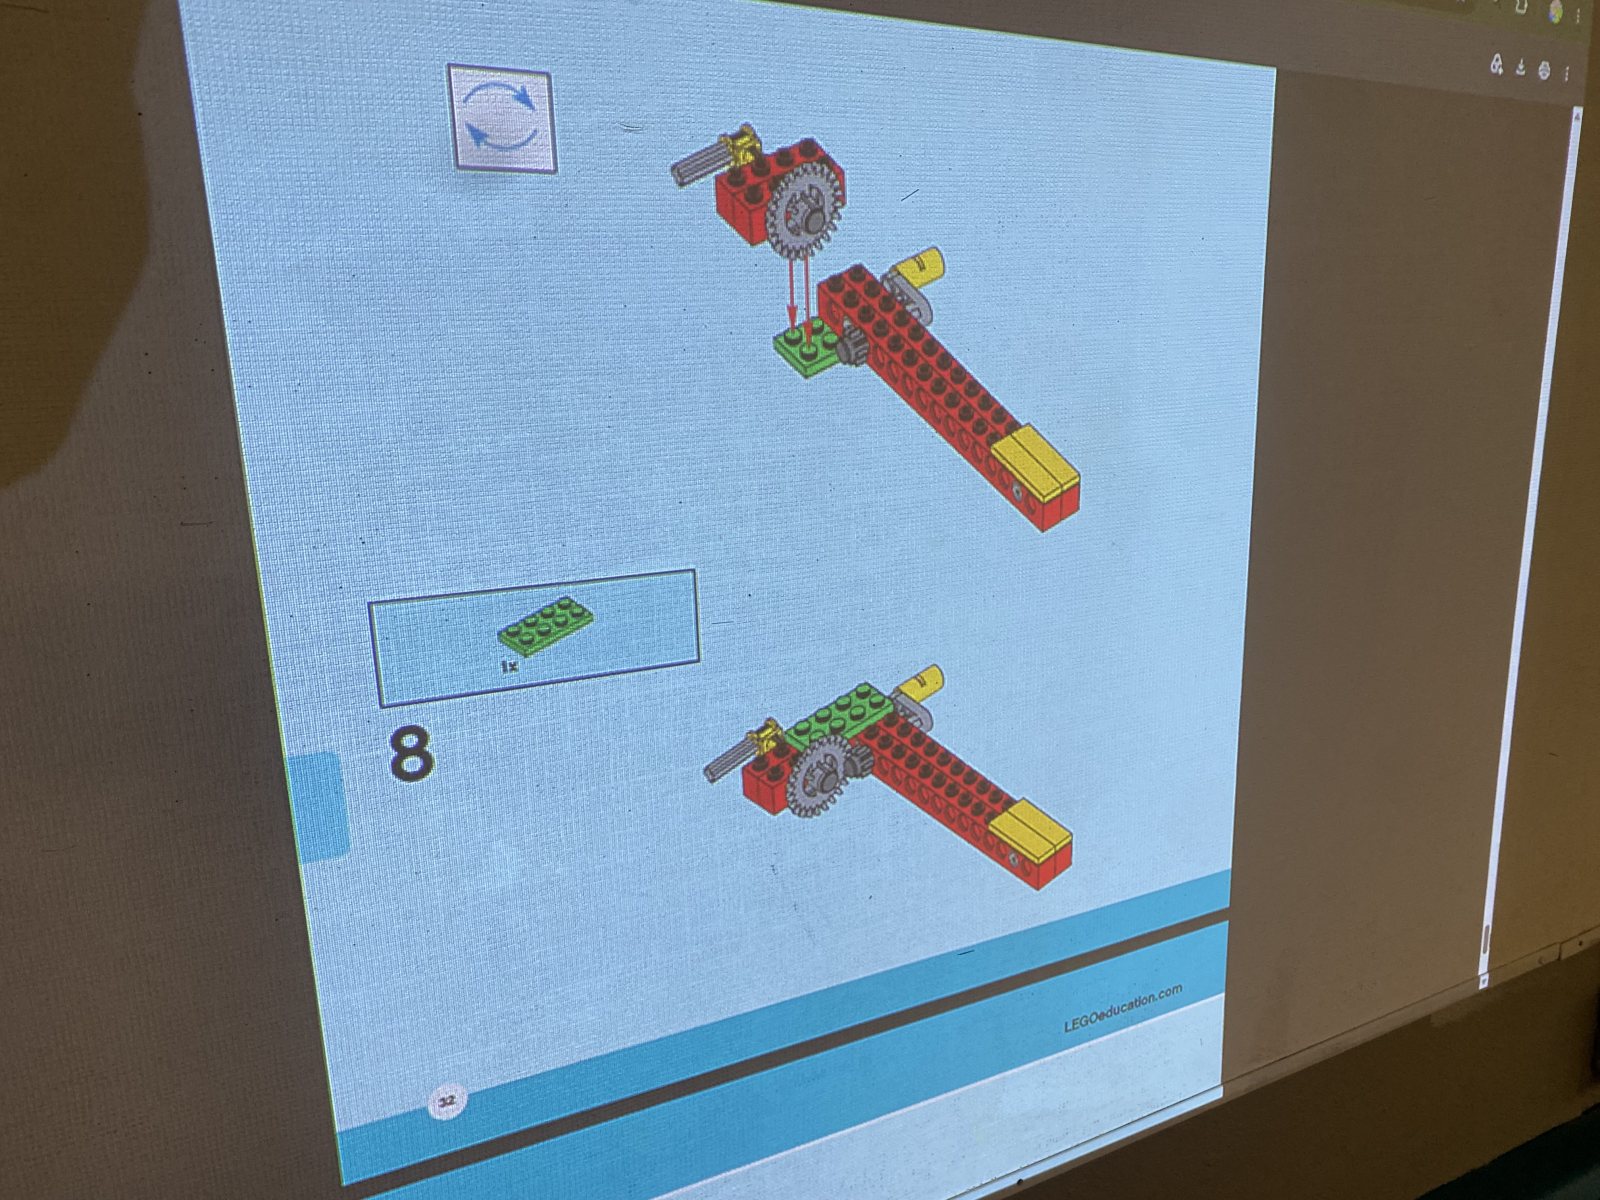
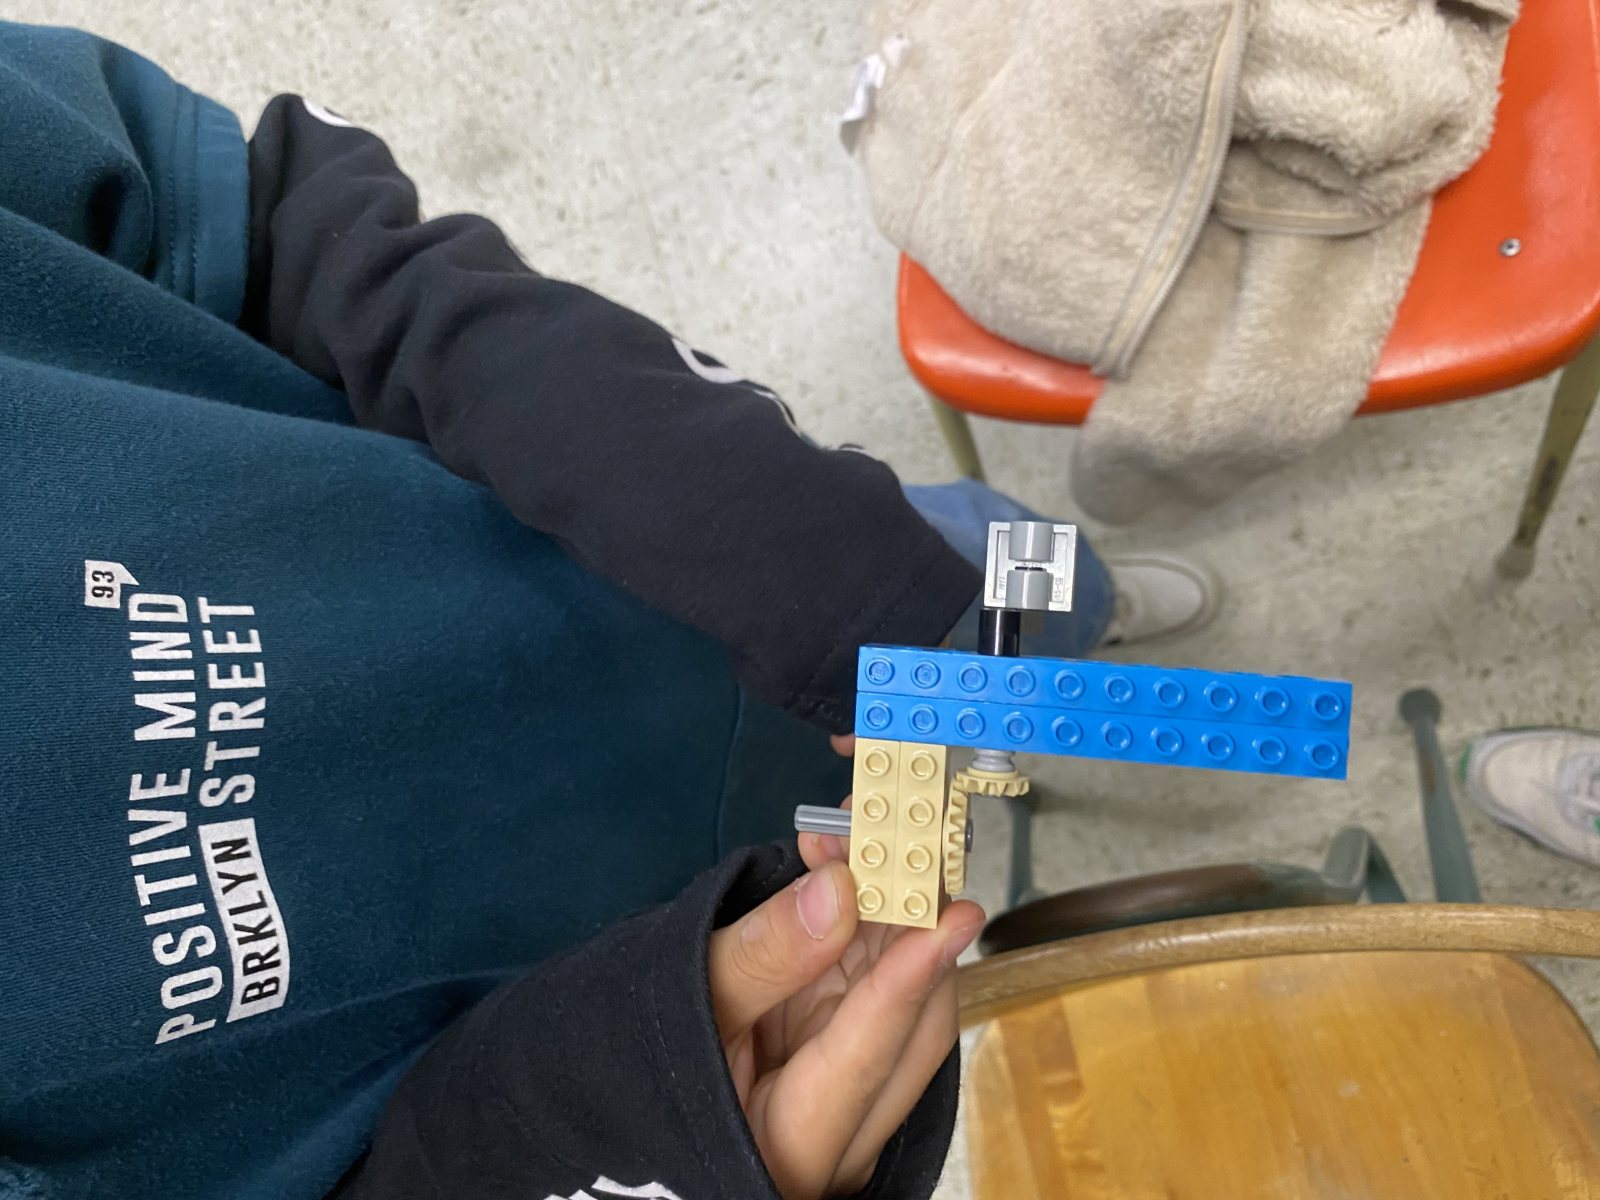
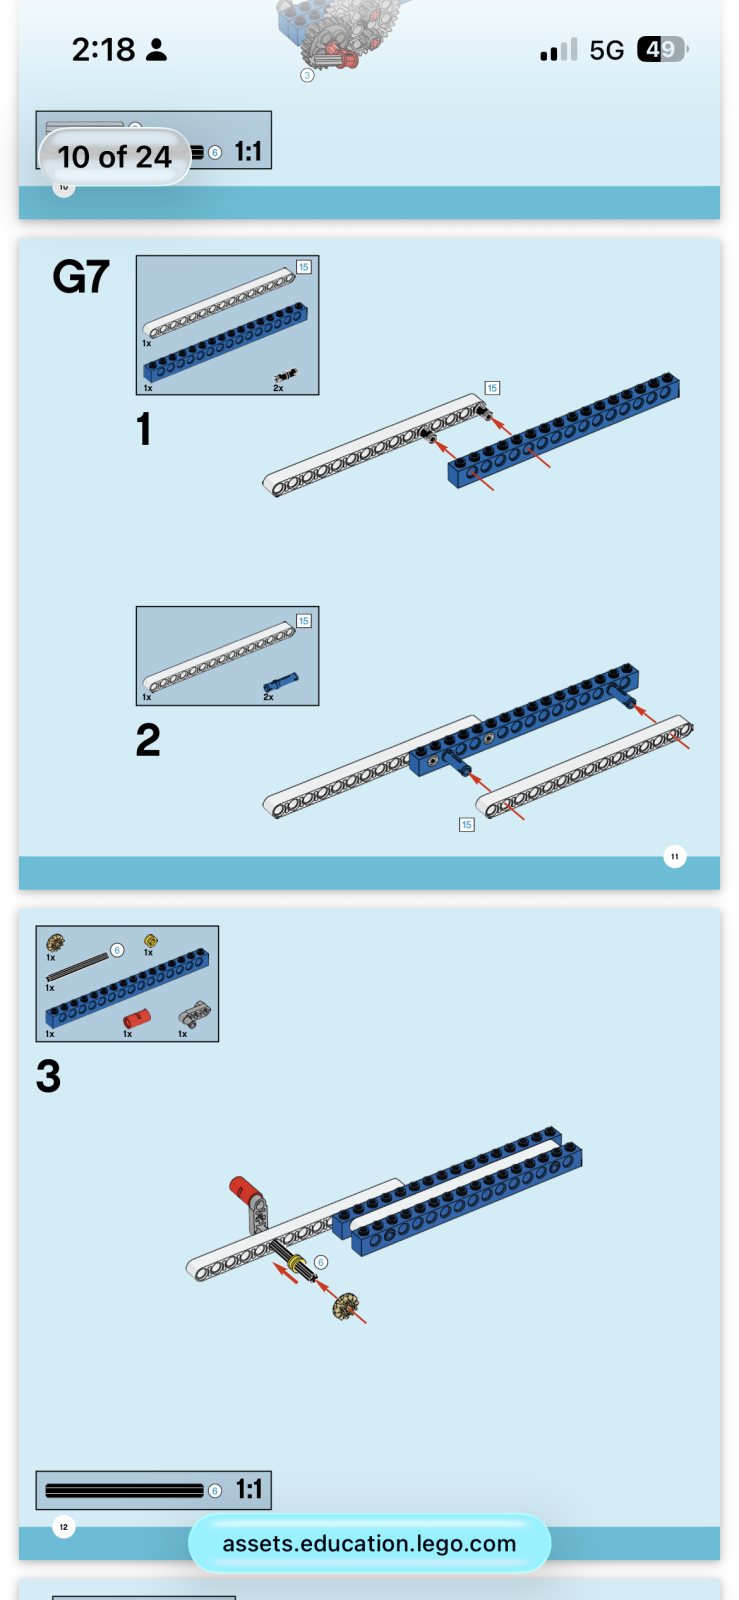
We explored several ideas about gears and how gears can be used to create and control movement. We also learned that motion does not always need to come directly from a motor. By using gears and simple mechanisms, we can transfer movement and create different actions for attachments. Class 3 materials: https://teamcastlegar.com/class3.php

Next week

Next week, we will: Build and program attachments for two missions. Finalize our Innovation Project presentation topic. Review which gear parts we still need and place an order for additional parts.
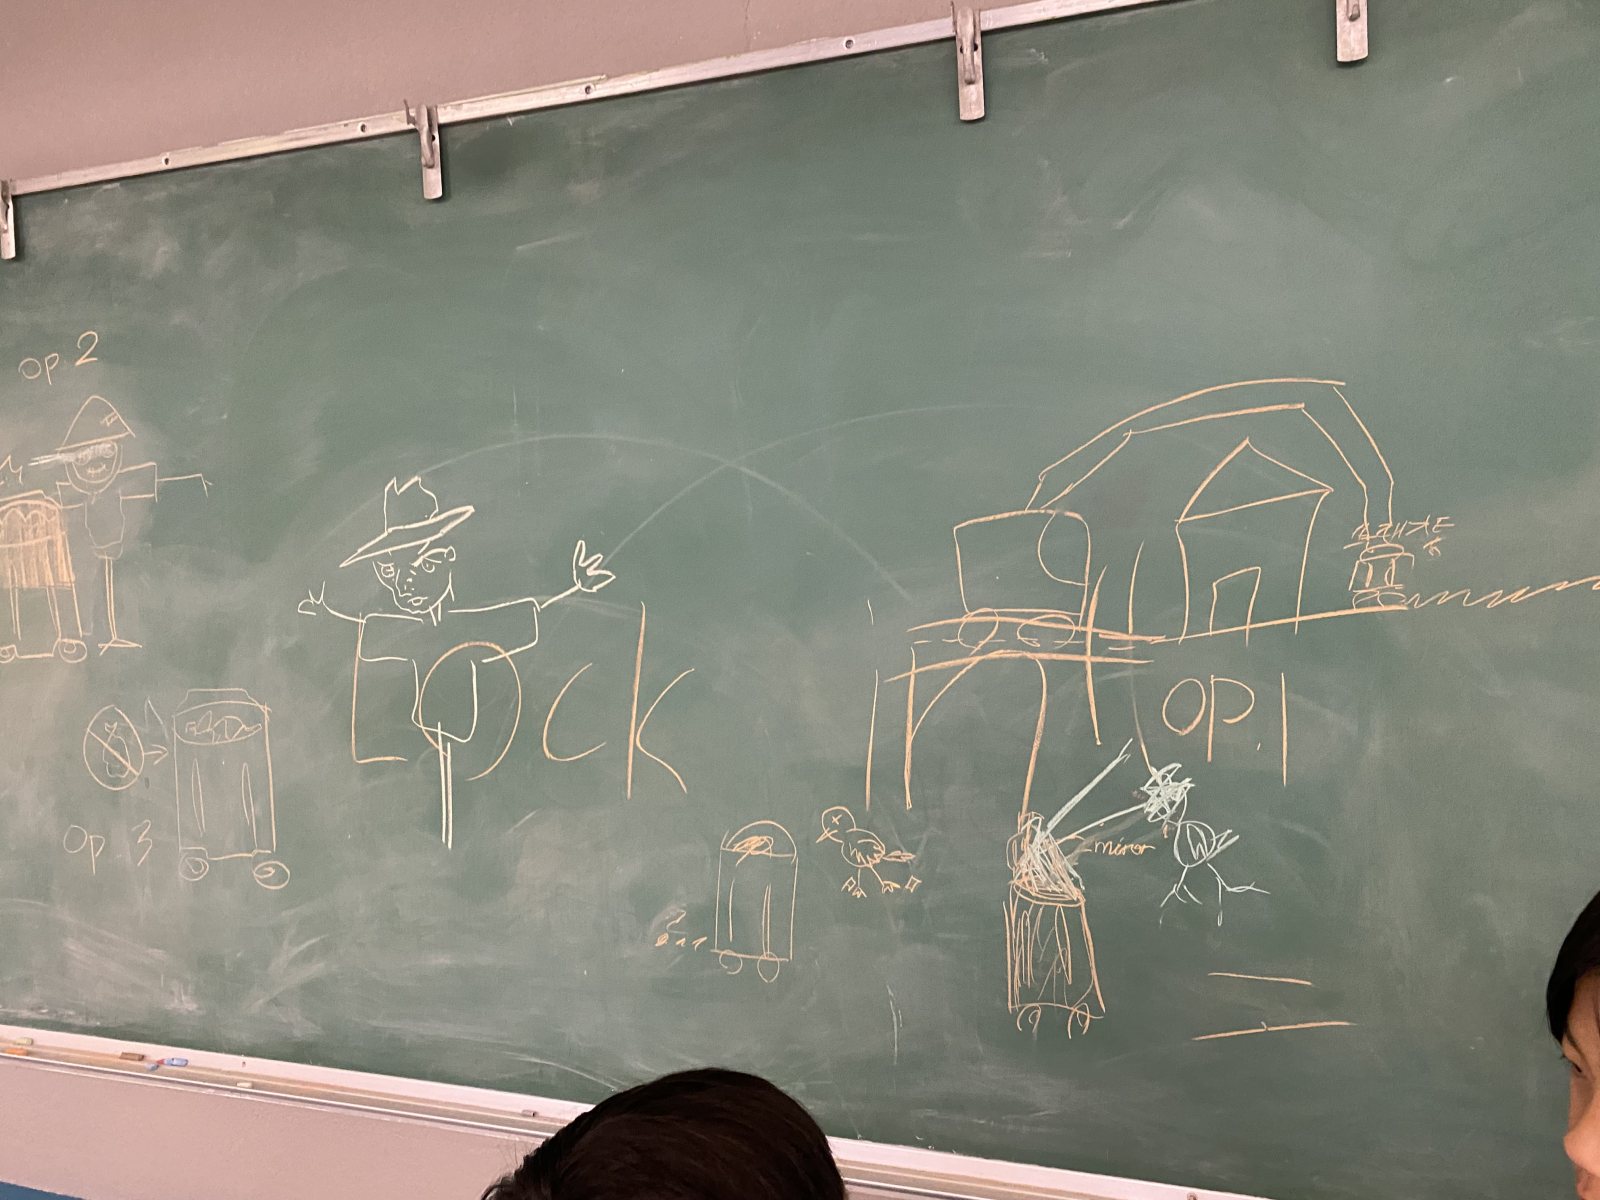
Team Castlegar Robot weekly meeting photo Team Castlegar Robot weekly meeting photo Team Castlegar Robot weekly meeting photo

Meeting 05

Learning Passive Attachments

This week, we checked which LEGO parts we are still missing and began learning more about attachment design. We focused on passive and gearless attachments and how simple mechanisms can help a robot complete missions efficiently.

What we did

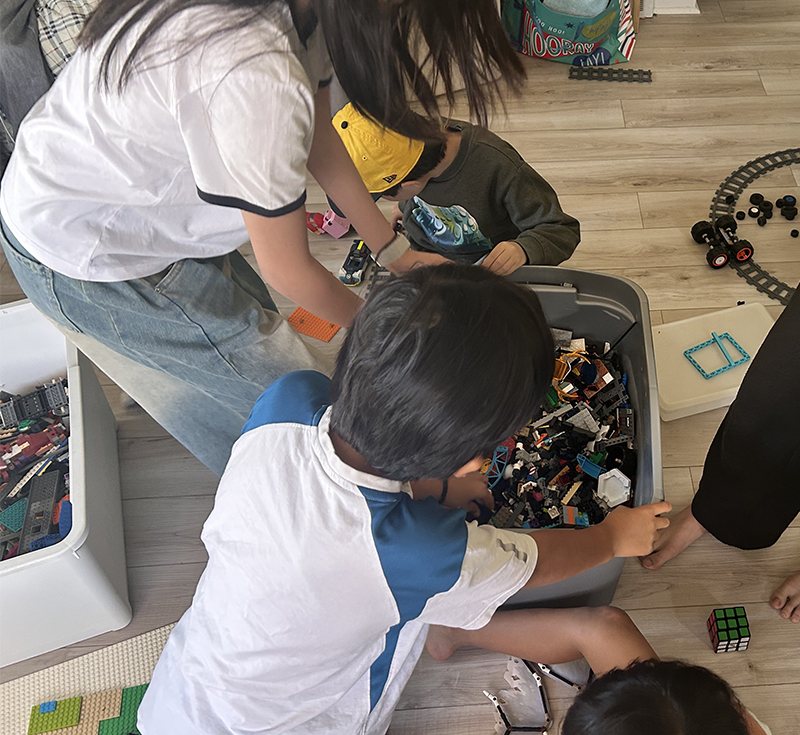
We reviewed our LEGO collection and identified parts that we are still missing for future robot building and mission practice. We also looked at different attachment ideas and discussed which types of parts and mechanisms may be useful for our team.

What we learned

We learned about the basic principles of passive attachments and gearless attachments. We explored how an attachment can move, release, push, or interact with a mission model without always needing an additional motor. We also looked at examples of how other teams use simple attachment designs to complete missions efficiently. Class 2 materials: https://teamcastlegar.com/class2.php

Next week

During the week, we will complete our competition registration. At our next meeting, we will divide into smaller groups and discuss ideas by topic so that each group can share its thoughts and help us decide our next steps.

Team Castlegar Robot weekly meeting photo Team Castlegar Robot weekly meeting photo

Meeting 04

Setting Up Our Competition Table

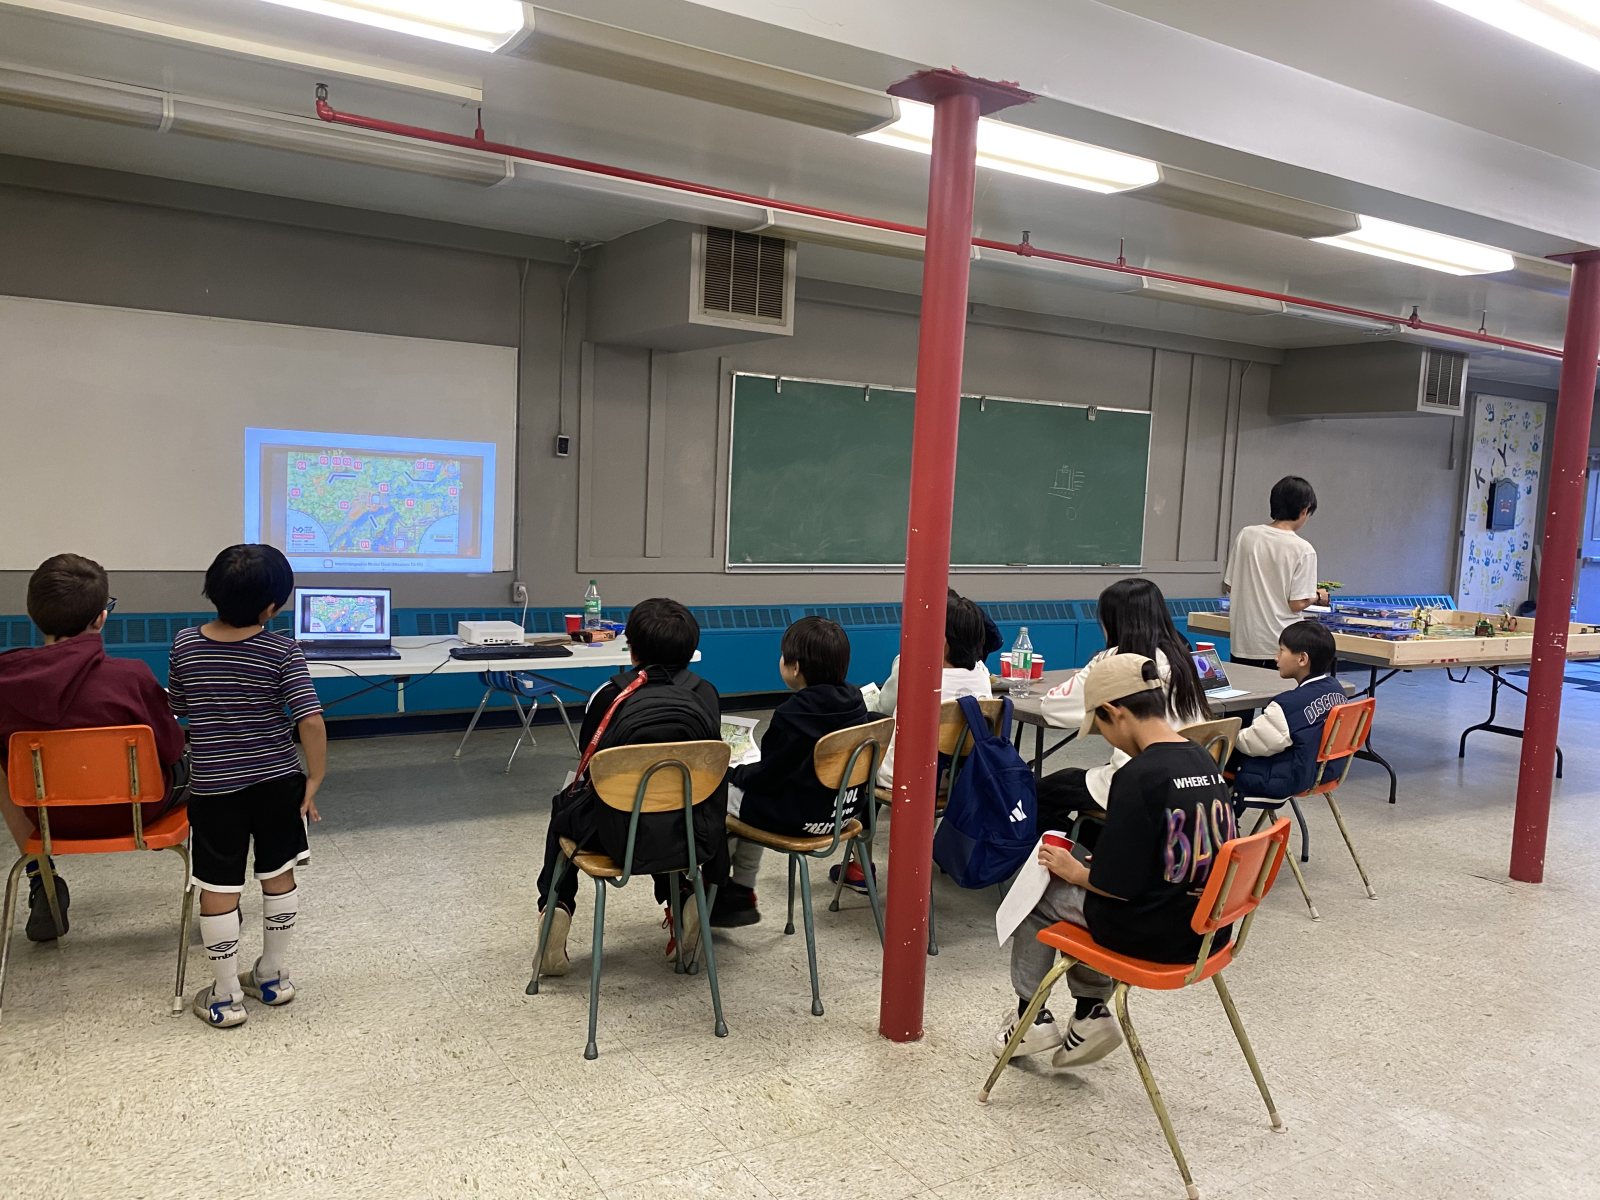
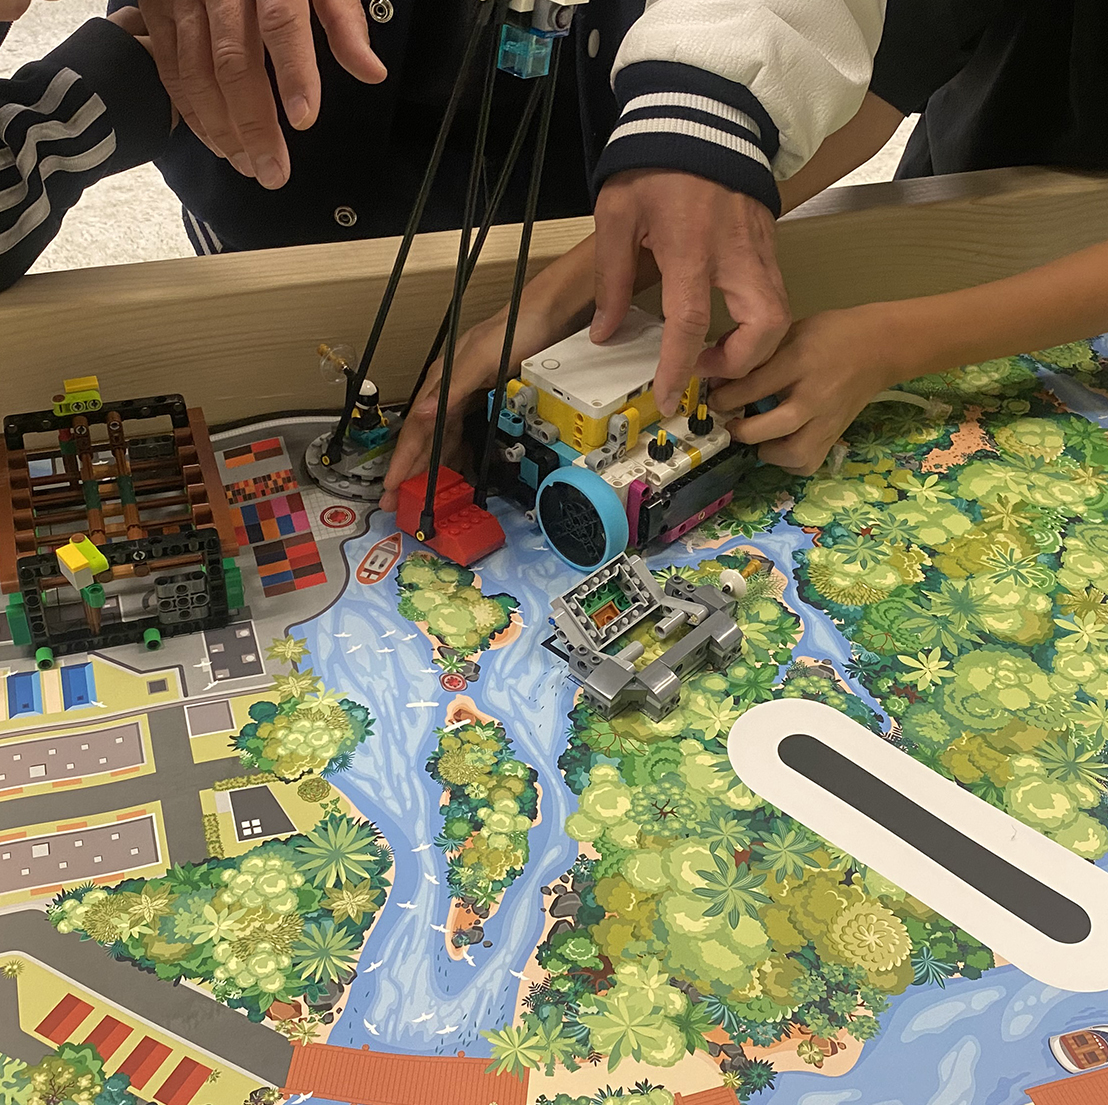
This week, we prepared our practice table and set up the official mission field. For the first time, we were able to look at the missions together and begin thinking about how our robot will eventually complete them.

What we did

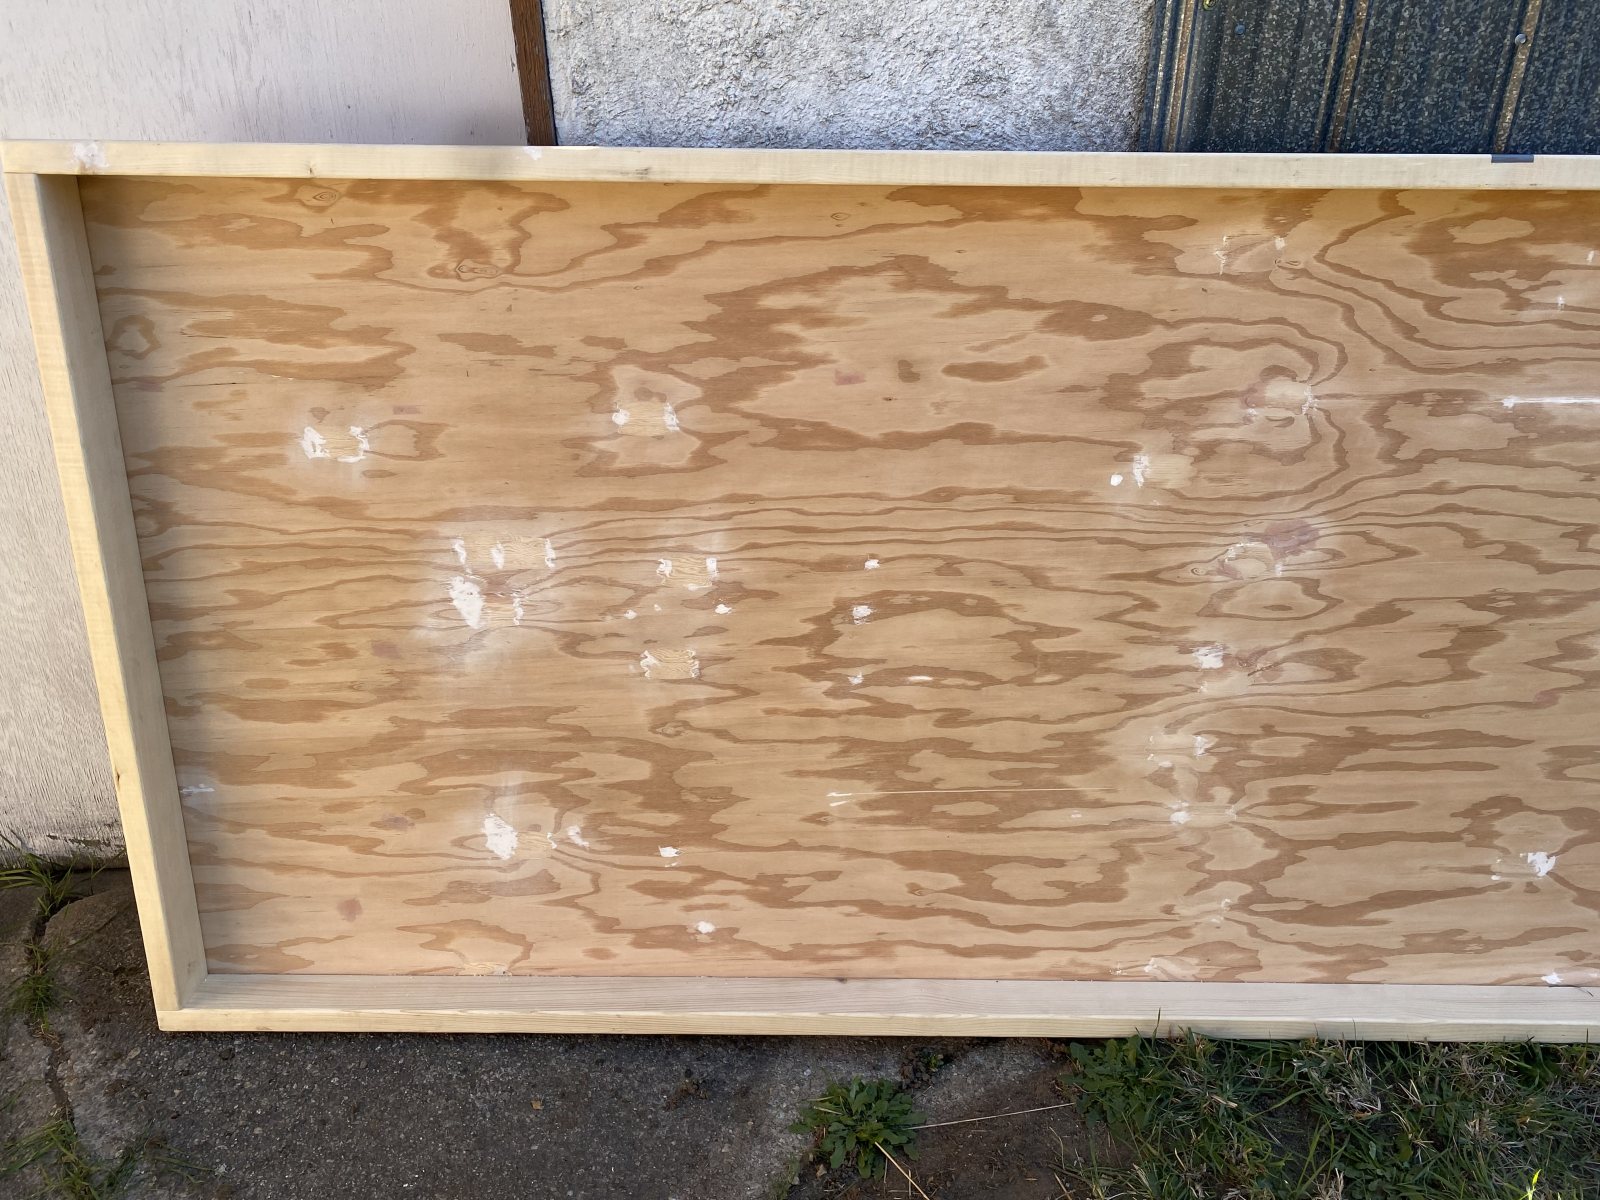
We worked on preparing our competition table by sanding the surface to make it smooth. Then we installed the mission mat and set up the mission models in their correct positions. Seeing the full field set up made the competition feel much more real and helped us understand what we will be working toward during the season.

What we learned

We looked through this season’s missions together and learned how many missions are on the field and what actions are required to earn points. Before using motors and programming, we used a very simple LEGO build and practiced moving it by hand. This helped us think about how the robot might approach different missions, interact with mission models, and return safely. We also reviewed examples of how other teams approach the Robot Game: https://teamcastlegar.com/class1.php

Next week

Next week, we will begin learning the basics of LEGO engineering, with a focus on gears. We will explore how different gears work together and how they can change speed, direction, and movement in our future robot designs.

Team Castlegar Robot weekly meeting photo Team Castlegar Robot weekly meeting photo Team Castlegar Robot weekly meeting photo

Meeting 03

Building, Organizing, and Planning Ahead

We continued organizing our LEGO collection and built a few simple models while waiting for our new parts to arrive. We also discussed possible Innovation Project topics, our team slogan, and T-shirt ideas. By the end of the meeting, we had a clearer idea of how we want to improve our LEGO organization and prepare for the Robot Game.

What we did

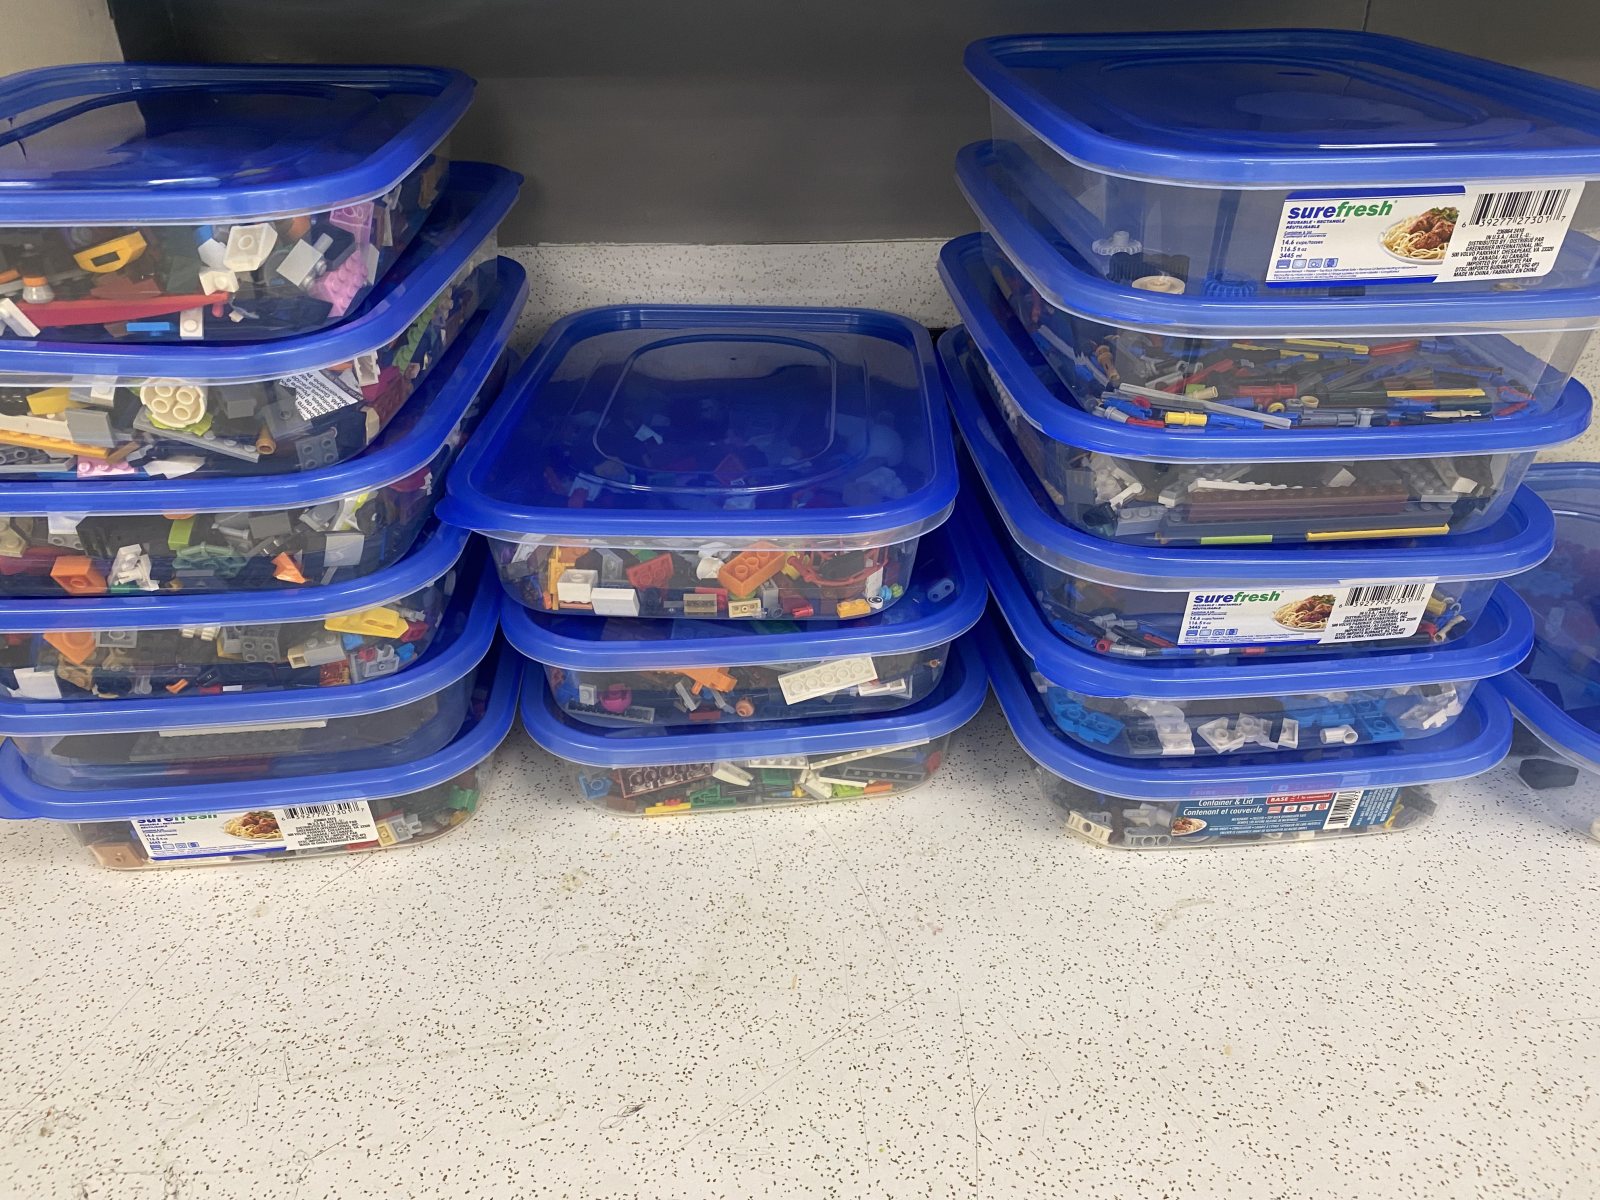
Our ordered LEGO parts still had not arrived, so we continued organizing our LEGO collection and built a few simple models by following LEGO instruction manuals. Because we had already spent time sorting the LEGO pieces, we were able to find the parts we needed more quickly. However, we also realized that our current organization system is not the best one yet. We need to improve it so that we can easily find special parts, become more familiar with different pieces, and use them more efficiently when we start building and engineering our robot. We also talked about several possible topics for our Innovation Project presentation. We shared many ideas, but we have not chosen our final topic yet. Finally, we discussed our team slogan and ideas for designing our team T-shirts. Interestingly, the LEGO parts we had been waiting for arrived right after our meeting ended!

What we learned

Organizing LEGO pieces really does help us work faster, but simply sorting pieces by type is not enough. We need a better system that helps us recognize special parts, understand how they can be used, and quickly find the right pieces for efficient building and engineering. We also learned that choosing a good Innovation Project topic takes time. We need to compare different ideas and think carefully about which topic will be meaningful, interesting, and possible for our team to develop.

Next week

Next week, we plan to get a table and set it up like a real FLL competition field. We will study the missions, learn what each mission requires, and look at how successful teams approach the Robot Game. We will begin thinking about our own strategy for completing missions efficiently and reliably.

Team Castlegar Robot weekly meeting photo Team Castlegar Robot weekly meeting photo

Meeting 02

A New Home for Our Team

We received some exciting support this week. Kinnaird Park Community Church generously offered us a space where our team can meet, build, and practice freely. We were also invited to a November event hosted by the Nelson Nerds team. With a new place to work and new opportunities ahead, Team Castlegar Robot is starting to feel like a real team.

What we did

We met in our new practice space for the first time and continued sorting our LEGO collection. As we organized the pieces, we realized that we did not have as many gears and Technic parts as we expected. To prepare for future robot builds, we ordered additional parts from both Canada and Korea, where we can receive genuine LEGO parts quickly. We also began thinking about how the different parts we already have could be used for engineering and robot design.

What we learned

We selected several gears, Technic parts, and a motor that we purchased for practice. Our challenge for the week is to think about and experiment with as many different ways as possible to connect and use these parts. This became our homework: explore how the same motor, gears, and LEGO pieces can create different kinds of movement and mechanisms.

Next week

We will discuss the robot we would like to demonstrate at the Nelson Nerds event and begin deciding on a topic for our Innovation Project presentation. We will also work together on creating our team T-shirts

Team Castlegar Robot weekly meeting photo

Meeting 01

Our First Meeting — The Beginning of Team Castlegar Robot

What we did

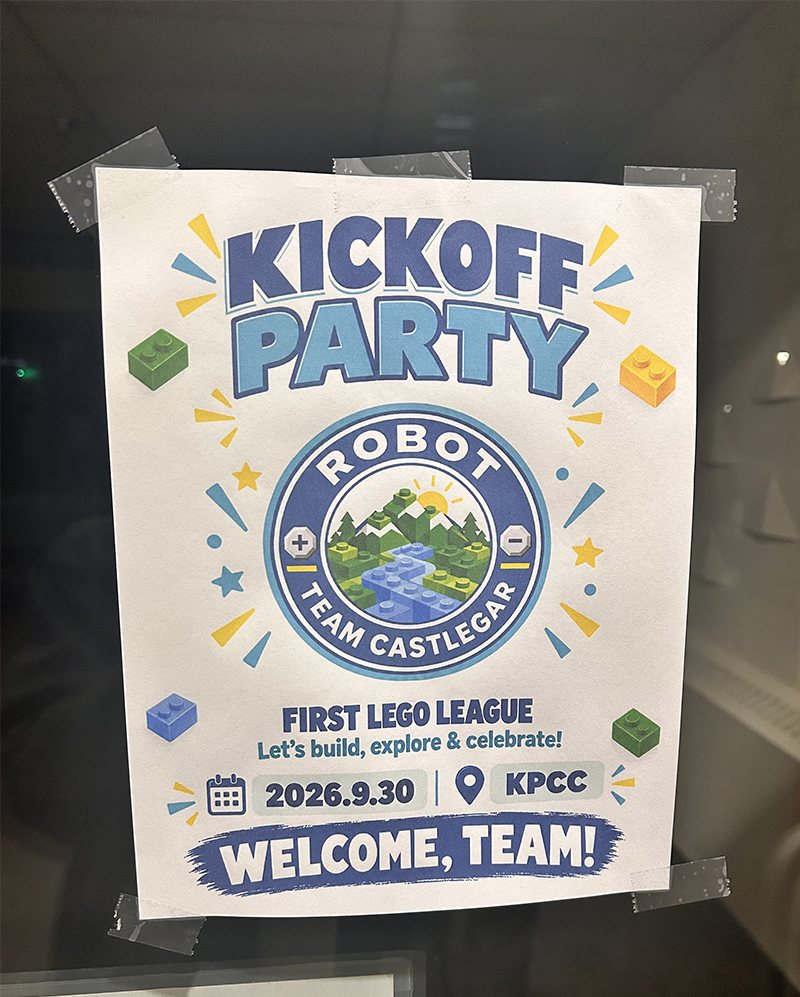
We met for the first time and started by sorting the LEGO pieces we already had. We organized them by function and type. Even after two hours, we had only finished about one quarter of the collection, but the process gave us some great ideas. As we looked closely at each piece, we began thinking about different ways it could be used and let our imaginations grow. After that, we had a kickoff party with our parents. It was a great way to celebrate the beginning of our journey together. This is how Team Castlegar Robot officially began.

What we learned

Even a single LEGO piece can inspire many different ideas. Taking time to organize, observe, and imagine helped us start thinking like a team.

Next week

We will choose our BIOGLOW Innovation Project topic and begin learning basic LEGO engineering concepts by building small individual models that demonstrate different mechanical functions and movements. We will also continue organizing our LEGO collection with help from volunteers.

Team Castlegar Robot weekly meeting photo Team Castlegar Robot weekly meeting photo